
 Tweet
OK. inertia wheels don't work. 10-4. whatever u say
-
-
AgreeOriginally posted by mike_kilroy View Post
We tried to help them but we did not have days to work it out.Originally posted by mike_kilroy View Post
Sonny knowing we were coming form a distance, should he not have warned us the device was not in ideal working condition, before we did the trip to measure it?
Not sure what you are trying to imply here?Originally posted by mike_kilroy View Post
What floor was originally working on is not the same magnet orientation as the Sonny Miller device. Floor uses the sides of the magnets and not the faces of the magnets as the Miller device. Big difference!Originally posted by mike_kilroy View Post
Also, just so you know, floor never heard of the Sonny Miller device till someone brought it to his attention several months after he had started his topic.
That is not correct!Originally posted by mike_kilroy View Post
Sonny Miller's device failed to demonstrate OU. In fact, as soon as the prony brake (20 ft/lb load) was engaged the power input to the device would go up by around 110 Watts.
The only credit I would give Sonny is, when I came back from the failed trip, I decided to build floor's device to see if it was a better solution since I had been following floor's topic months before knowing of Sonny's device.
As you say, this is your "opinion" and has nothing to do with facts.Originally posted by mike_kilroy View Post
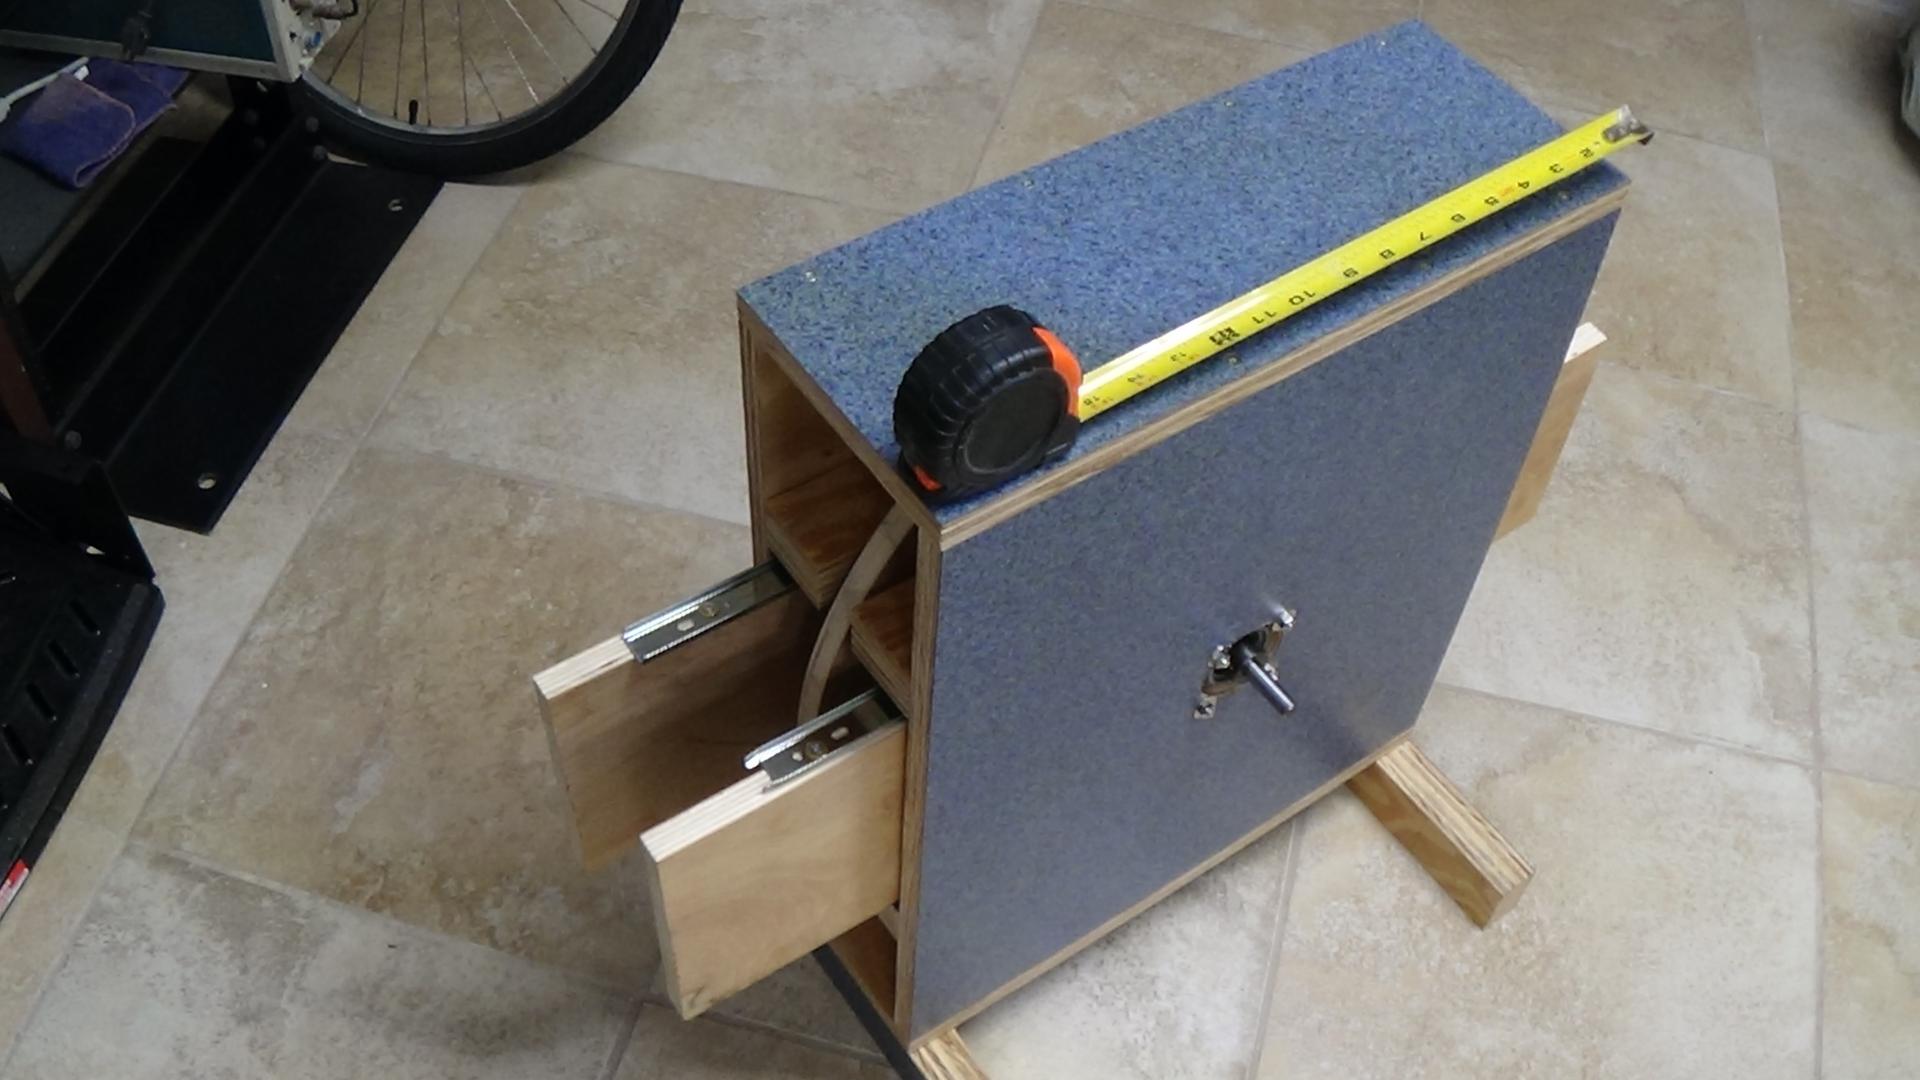
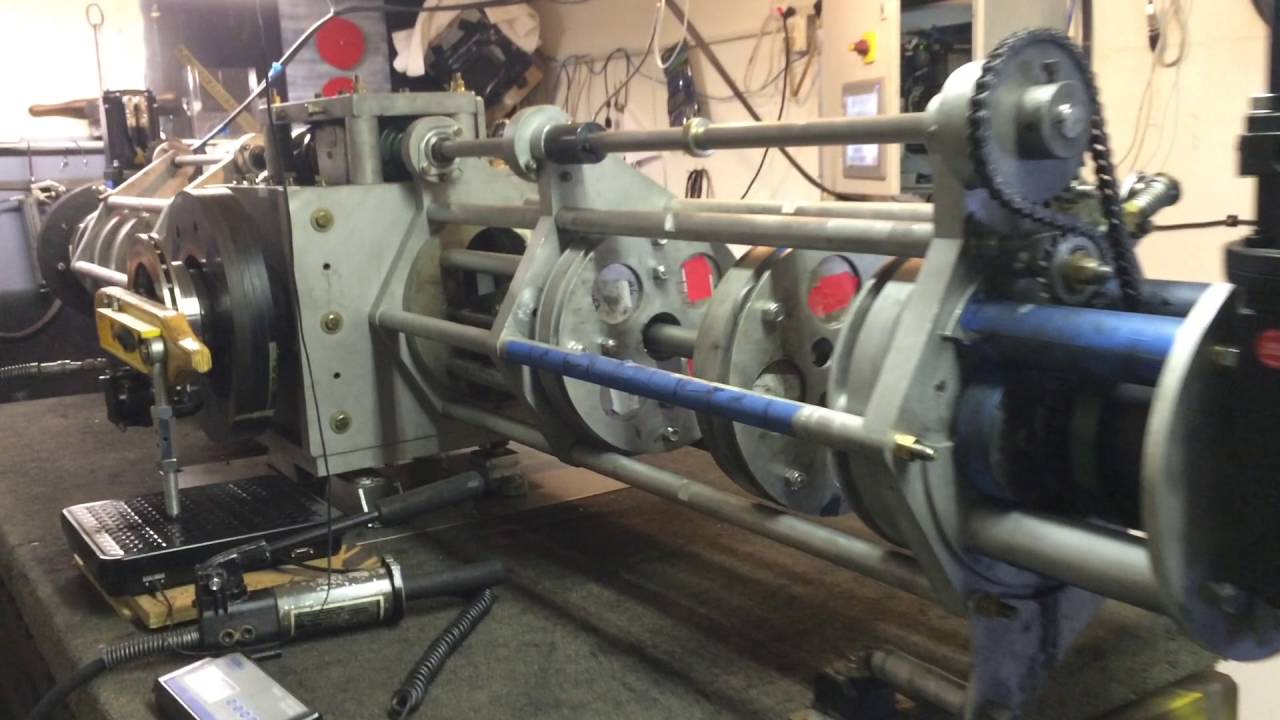
The newest (v.2) of the my test device which is a variation of floor original design and a design of my own, will not need servo motors to make it work. That should tell you it's not based on Sonny's design. It looks nothing like it!... see below picture to compare.Originally posted by mike_kilroy View Post
My device then Sonny's device. Anyone see any resemblance?
I did send Sonny an email after returning from testing his device. The email contained links to my videos of old magnet motors I designed.Originally posted by mike_kilroy View Post
Never got a reply.
So we need to ask our self's, why the fuss now?
Sincerely
LucAttached FilesLast edited by gotoluc; 03-05-2017, 12:08 AM.Comment
-
-
additional clarity and an error mentioned
from here TD replications
Luc
quote
I now see a terrible error!... the 16.125 inches was for each section of disengage then engage. So the 16.125 inches would have to be multiply by 2 = 32.25 inches of outer rotor traveled for 180 degrees, making the rotor 20.53 inches in diameter and the device under unity from the calculated math.
So the input rotor traveled 6.45 times the distance of the output. So input average is 1.1Kg x 6.45 = 7.1Kg input to 6.25Kg of output so under unity by about 12%
I'm so sorry for your trouble and expenses.
Please accept my apology.
At everyone, please accept my apology for the trouble my over site may of caused
Kind regards
Luc
end quote
so for Clarity
this experiment is considered underunity
however
*also to note
Butch Lafonte has been researching these interactions for many many years
someone playing with his work below ,as well as his you tube Channel
for consideration ?
and Butch's channel
If you want to Change the world
BE that change !!Comment
-
replication
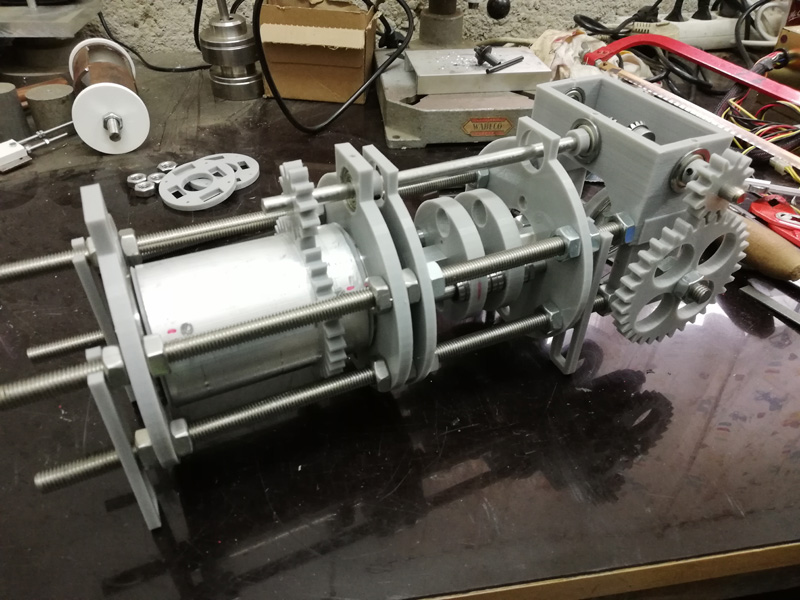
here si my simple replication of this motor... but for now it is not working... i will try some adjustments and add flywheel...
YT video
see ya Attached Files
Comment
-

Comment